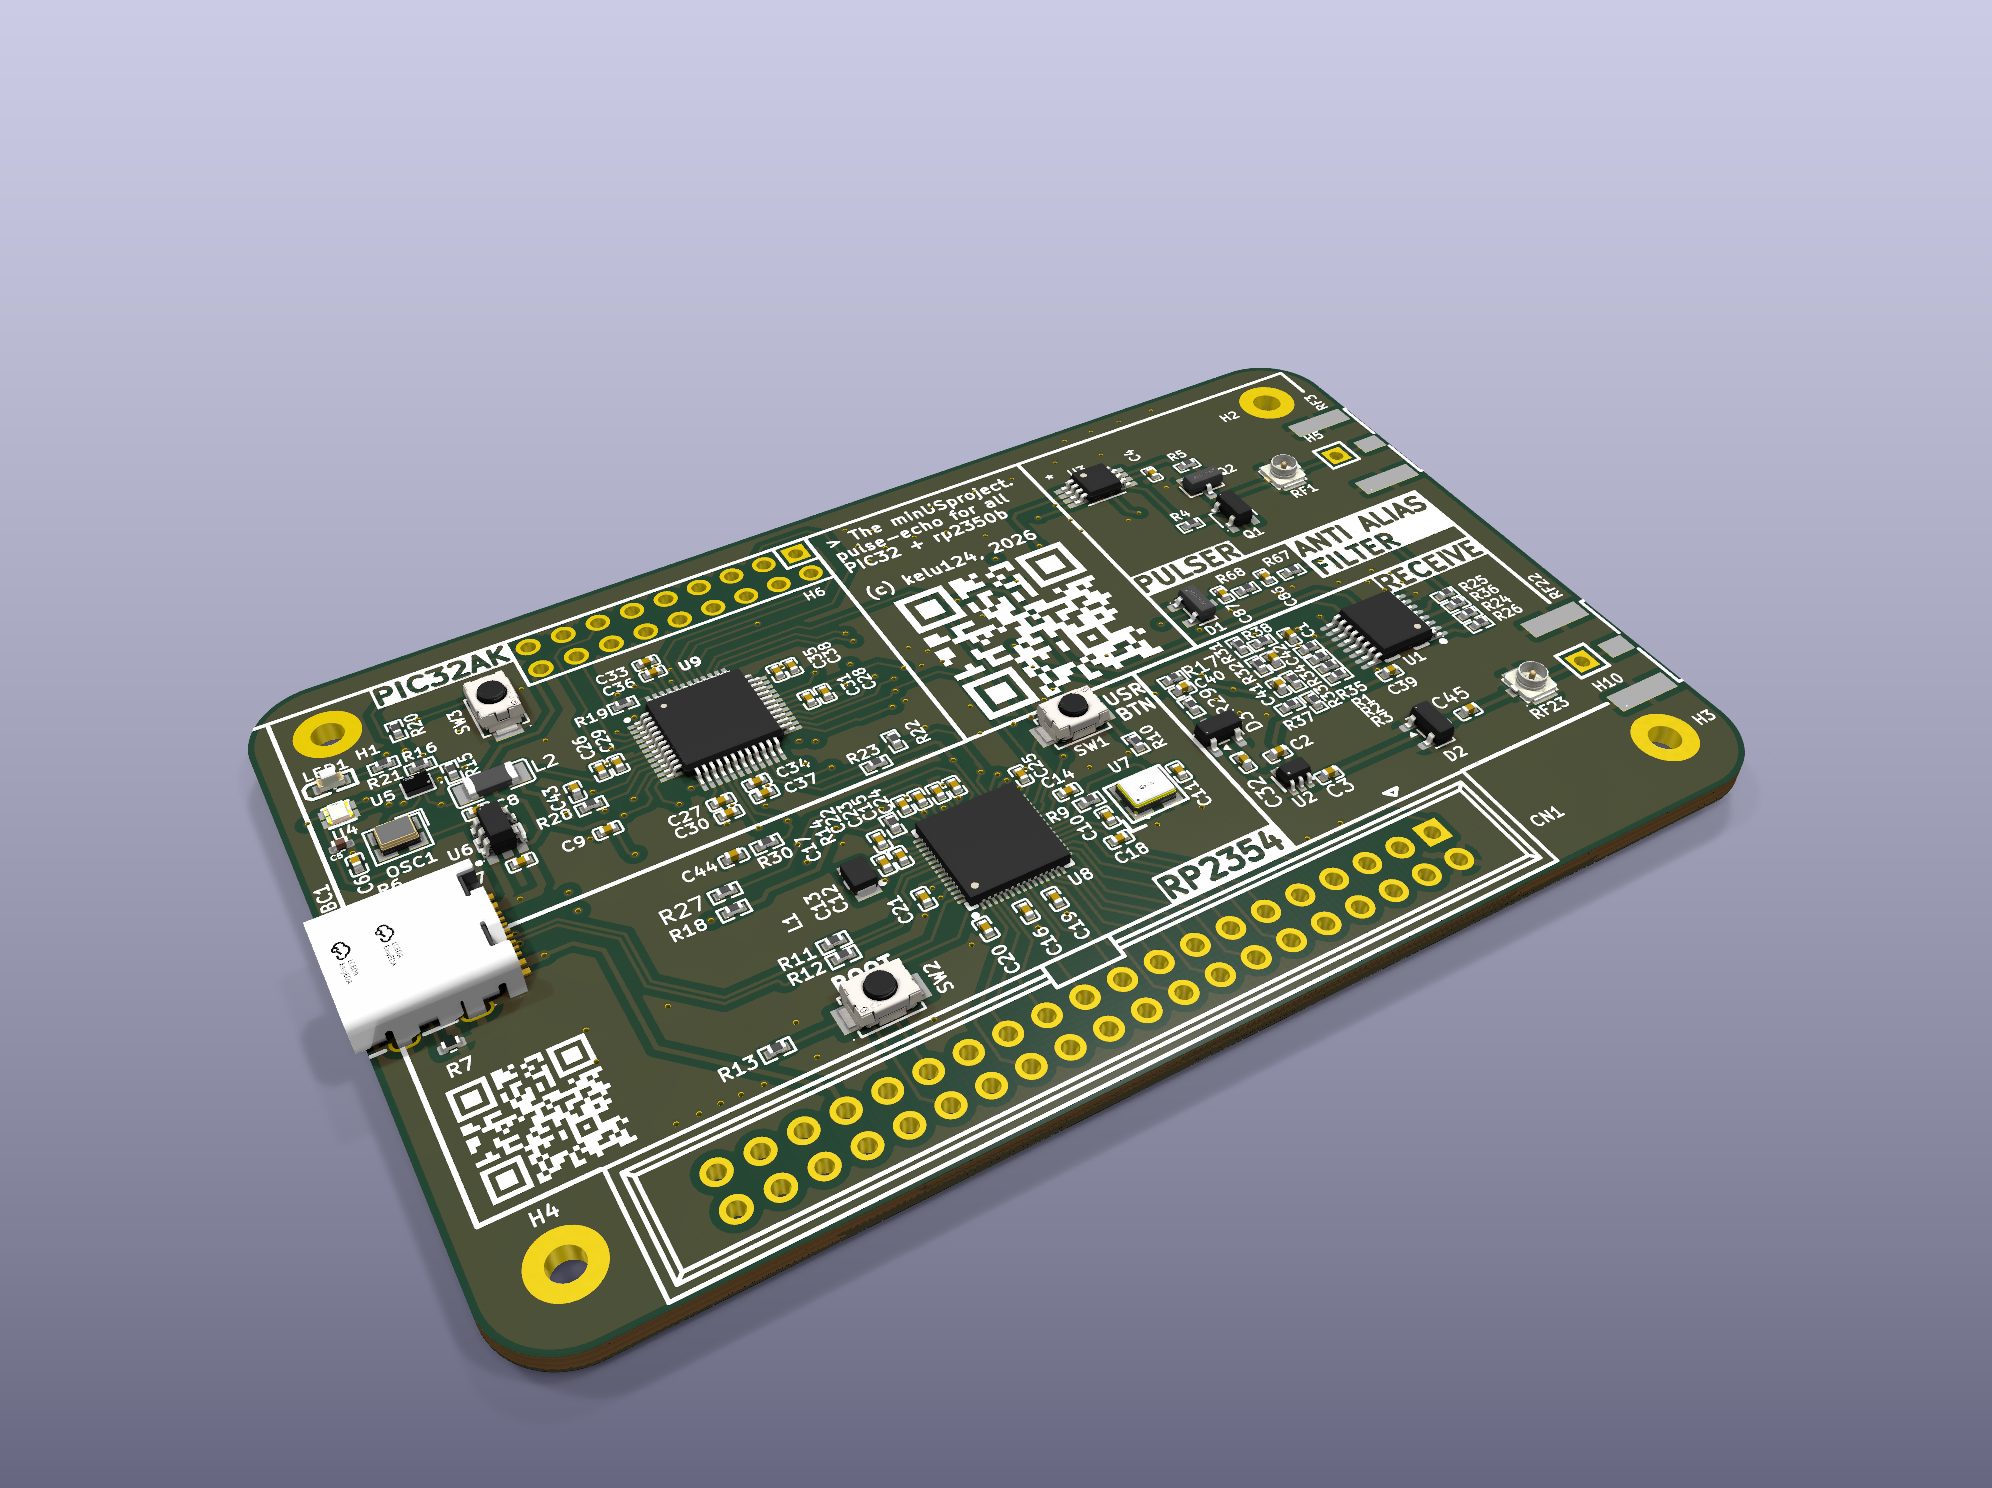
A minimal, single-channel, low-cost, open-source ultrasound pulse-echo platform — built as a conference-workshop badge.
minus drives one piezo transducer with a high-voltage pulse, amplifies and digitizes
the returning echo, and streams the raw data to a host. It is designed to be cheap,
small, simple, and hackable: a badge attendees can use in an ultrasound-conference
workshop (e.g. muscle-contraction monitoring, A-/M-mode) and then extend and
experiment with (coded excitation, on-device DSP, add-on boards). See docs/intended-use.md.
⚠️ Status: working prototype (minus v1.1, board
minUS_08112026). Pulse-echo, the switchable RX gain, the fixed-pattern correction and the RGB LED work on the bench, and the datasheet rev 0.2 gives measured figures, errata and the test transducer (Annex A). Firmware RP2354A 1.1.2, PIC32AK 1.1.0, link protocol 10. Source: https://github.com/kelu124/minus. Non-clinical, for research / education / NDT only; not a medical device.
What it is (at a glance)
- Two MCUs: a Raspberry Pi RP2354A (USB-C console, pulse timing via PIO, gain mux, LP5562 RGB LED over I²C, ICSP programmer for the PIC) and a Microchip PIC32AK1216GC41048 (on-chip ADCs and op amps: captures the A-line, 4095 samples at up to ~25 Msps).
- Front end: TC4427/MIC4427-driven 3-level pulser → protected RX → two-stage op-amp gain (4 legs per stage via analog mux, ×1 bypass) → PIC ADC.
- Transducer: 3–4 MHz single-element piezo, separate TX and RX connectors (SMA + U.FL); raw RF A-mode.
The probe used for all measurements is characterised from its S11 in datasheet Annex A
(
datasheet/piezo_test/). - Open: open hardware + firmware + docs, designed for JLCPCB fabrication (see LICENSE.md); OSHWA certification planned.
Repository map
| Path | What’s there |
|---|---|
hardware/ |
KiCad project of the current board (minUS.kicad_pro, minus v1.1 = minUS_08112026), production/ JLCPCB outputs (Gerbers zip, BOM, positions), 3D renders + render_3d.py. |
firmware/ |
rp2354/ (pico-sdk) and pic32/ (XC-DSC) sources, built images committed in */build/, VERSIONS.md. |
python/ |
minus Python library (one method per CLI command, firmware-sync check, offline tests) + step-by-step notebooks. |
datasheet/ |
Product datasheet rev 0.2 (LaTeX source, generated values/figures, minus-datasheet.pdf); piezo_test/ = test-probe S11 (Annex A). |
docs/bench/ |
Bench campaigns: raw captures, capture/analysis scripts and a README per campaign (pulse-echo, gain, noise, pattern correction, datasheet, E3 comb-phase jitter). |
docs/claude/ |
Working notes: session logs, decision memory, TODO/DONE, changelog. |
TODO_HARDWARE.md |
Corrections queued for the next board revision. |
LICENSE.md, LICENSES/ |
Per-folder licenses. |
Earlier material (the requirements and trade studies, the survey of comparable systems, reference designs, the devkit and intermediate boards, and source PDFs) was removed on 2026-11-19 to keep the tree focused. It is still in the git history before that date.
Getting started
Requirements (tested on Ubuntu 22.04, x86-64)
Flashing only (the images are prebuilt): a USB-C cable and nothing else. The RP2354A
takes the .uf2 over its USB bootloader, and then programs the PIC itself.
Building the RP2354A firmware:
- pico-sdk 2.1.0 with
PICO_SDK_PATHset,arm-none-eabi-gcc,cmake,ninja. picotool(2.3.0 tested) is optional: you can copy the.uf2to the boot drive instead.
Building the PIC32AK firmware. The PIC32AK is a dsPIC33A-core part, so it is compiled by MPLAB XC-DSC, not XC32:
- MPLAB XC-DSC ≥ 3.31.01 (3.31.01 tested, it lists
32AK1216GC41048). Get the Linux.runfrom https://www.microchip.com/xcdsc,chmod +xit, run it withsudo(it installs to/opt/microchip/xc-dsc/vX.YY), then add itsbin/toPATH. - Device Family Pack
Microchip.PIC32AK-GC_DFP(1.1.53 tested) from https://packs.download.microchip.com/. The.atpackis a zip: unpack it to~/microchip/packs/PIC32AK-GC_DFP/1.1.53/. MPLAB X can also install it (Tools → Packs). - MPLAB X IDE (6.35 tested): only needed to flash the PIC with a Microchip tool, through
ipecmd. Keep “MPLAB IPE” ticked in the installer. It takes ~3 GB and also installs ~8 GB of device packs, so keep ≥ 2 GB free on/. For programmer access without root, install Microchip’s udev rules (/etc/udev/rules.d/z010_mchp_tools.rules), then runsudo udevadm control --reload && sudo udevadm triggerand replug. - Optional Microchip programmer on J1 (Tag-Connect TC2030-NL, ICSP pinout 1 MCLR · 2 VDD ·
3 GND · 4 PGD · 5 PGC · 6 NC). MPLAB Snap or PICkit Basic (~€30 each), or PICkit 4/5,
ICD 4/5, ICE 4. These do not power the target, so keep the board on USB-C. In normal use the
RP2354A programs the PIC (
pic flash), so you don’t need one.
make -C firmware/pic32 info shows the XC-DSC / MPLAB X / DFP paths the build will use. The
Makefile already passes the two flags XC-DSC needs for this part: the device linker script
-T <DFP>/xc32/support/PIC32A/gld/p32AK1216GC41048.gld and -mdfp= for xc-dsc-bin2hex.
Python library, bench scripts, datasheet: Python 3 with pyserial and numpy (plus matplotlib and
jupyter for the notebooks and plots); pdflatex for the datasheet (make -C datasheet).
Build
make -C firmware/pic32                        # -> firmware/pic32/build/minus_pic.hex
cmake -S firmware/rp2354 -B firmware/rp2354/build -G Ninja -DCMAKE_BUILD_TYPE=Release
cmake --build firmware/rp2354/build -j        # -> firmware/rp2354/build/minus_rp.uf2
Build the PIC first: the RP image embeds the PIC hex (tools/hex2c.py → build/pic_image.c).
make -C firmware builds both, in that order. Commit the two images with every version bump
(see firmware/VERSIONS.md).
Flash and test
- RP2354A: hold BOOTSEL (SW2) and tap RUN (SW1). If a firmware is already running, type
reboot dfuon its console instead. A UF2 drive appears: copyfirmware/rp2354/build/minus_rp.uf2onto it, or runpicotool load -x firmware/rp2354/build/minus_rp.uf2. Wait for/dev/ttyACM0to come back. - Console:
picocom /dev/ttyACM0(any baud; it is USB CDC), or one-shot from a script withpython3 firmware/rp2354/tools/rpcli.py /dev/ttyACM0 "version" --wait=1. Typehelpfor the command list, thenversionand check the version numbers before going further. - PIC32AK, from the RP:
pic idmust print… DEVID 0x9da2 DEVREV 2 -> PIC32AK1216GC41048, then runpic flash(erase, program, verify, ~1 s). It writes the PIC image embedded in the RP firmware, so checkversionfirst. With a Microchip tool on J1 instead:make -C firmware/pic32 flash TOOL=SNAP(orPKBASIC,PK4,PK5,ICD4,ICD5,ICE4). - Link check:
ping→ok;raw ID?→PIC32AK1216GC41048 minus-pic32 1.1.0 proto 10;rgb 0 255 0→ LED green (25 % brightness by default;rgb 0 255 0 100= full). - Pulse-echo:
pefires the pulser and captures one A-line, andgain [leg [u1 [u2]]]sets the RX gain. The full command reference and pin map are infirmware/README.md. Measurement campaigns to reproduce are indocs/bench/. - From Python:
pip install -e python/library, then followpython/notebooks/(from minus import Minus; dev = Minus(); dev.pe()). Seepython/README.md.
Known limitations
The full list is in the datasheet errata; the ones that matter when you use the data:
- Sample-comb phase (E3): the pulse falls anywhere within one 40 ns sample from shot to shot, and in 14–31 % of captures
the comb slips by a whole sample during the capture. Align shots on the echo of interest before averaging
(
docs/bench/2026-11-19-jitter/). - ADC slow lock (E2): detected on the PIC;
peandacqre-shoot automatically. - Link speed: 115 200 Bd between the MCUs, so one 4095-sample shot takes ~0.9 s end to end.
- TX and RX are separate nets: a single-element probe on one connector needs an external tee for now.
Keeping firmware and Python in sync
python/library is checked against the firmware sources (commands, help usages, link protocol, versions, a fingerprint
of every source file) by python -m minus.fwsync. It runs automatically after firmware edits in Claude Code and on
git commit; enable the git hook once per clone with git config core.hooksPath .githooks. Details in
python/README.md.
Lineage & credits
minus builds on the open single-channel ultrasound work of Luc Jonveaux (kelu124):
echomods/Murgen,
un0rick,
lit3rick, and
pic0rick. It reuses their proven building blocks
to reduce risk.
License
Hardware: TAPR OHL v1.0. Firmware, Python library and scripts: GPL-3.0-or-later. Documentation, datasheet and bench data: CC-BY-SA-4.0. Details and third-party exceptions are in LICENSE.md.